Industrial Communication
-
CSS Electronics - CANsub.2: 2 x CAN Bus Interface (USB + Ethernet)0,00 €
This 2 x CAN FD interface lets you stream CAN bus data in real-time via USB/Ethernet - with pro specs, built-in LCD display and zero software installation.
The free webCAN app is hosted offline on the CANsub - simply enter the device URL in a browser to start. This lets you instantly send/receive CAN frames, DBC decode data and plot CAN signals from any connected PC, tablet or phone.
The device provides an open REST/WebSocket API that lets you easily build 3rd party apps - with plug & play integrations for e.g. Python and SavvyCAN.
Ideal for CAN bus diagnostics, OEM development, field service, automation, sniffing and dashboards.
Need 4 x CAN? See the CANsub.4!
-
CSS Electronics - CANsub.4: 4 x CAN Bus Interface (USB + Ethernet)0,00 €
This 4 x CAN FD interface lets you stream CAN bus data in real-time via USB/Ethernet - with pro specs, built-in LCD display and zero software installation.
The free webCAN app is hosted offline on the CANsub - simply enter the device URL in a browser to start. This lets you instantly send/receive CAN frames, DBC decode data and plot CAN signals from any connected PC, tablet or phone.
The device provides an open REST/WebSocket API that lets you easily build 3rd party apps - with plug & play integrations for e.g. Python and SavvyCAN.
Ideal for CAN bus diagnostics, OEM development, field service, automation, sniffing and dashboards.
Need 2 x CAN? See the CANsub.2!
-
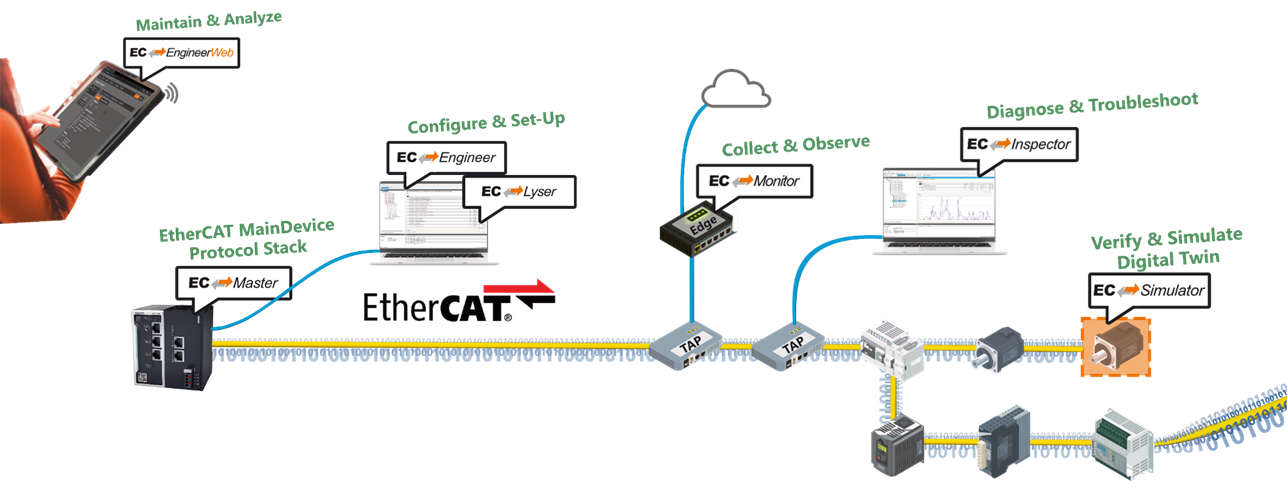
acontis - EtherCAT communications control0,00 €
Introduzione alla tecnologia EtherCAT e al protocollo EtherCAT
-
CSS ELECTRONICS - CANmod.router: 4 x CAN to 1 x CAN (or USB) Converter0,00 €
The CANmod.router lets you receive/transmit CAN data (Classical or FD) from/to 4 isolated secondary CAN buses via 1 primary CAN bus (or USB).
The compact module is 100% standalone (no PC required) and offers pro specs, daisy chaining and powerful configuration options.
It can e.g. be used with the CANedge, enabling you to log 5 x CAN buses (or beyond via daisy chaining).
The device can also be used as a powerful 4 x CAN FD to USB interface with free software/API tools.
Tip: Add the DB25-to-4x-DB9 for quick installation.
-
CSS Electronics - ISOBUS DBC File - Decode Tractor Data [ISO 11783-7 Database]0,00 €
The ISOBUS DBC file contains decoding rules for converting raw CAN bus data to 'physical values' (m/s, %, ...). This lets you easily decode data from agriculture vehicles like tractors.
DBC is a CAN database format used in most automotive tools - incl. our CAN software/APIs.
The download includes the ISOBUS DBC and Excel file based on the public ISO 11783-7 PGN/SPN data. The cost is a one-time fee.
See also our J1939 DBC and NMEA 2000 DBC, both of which can be relevant in agriculture vehicles.
-
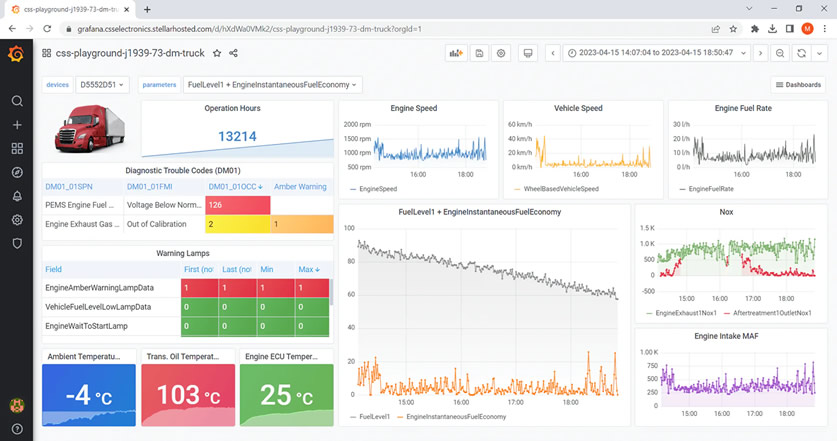
CSS Electronics - J1939-73 DBC File - Heavy Duty Diagnostics (DM1, DM2, ...)0,00 €
The SAE J1939-73 DBC file contains decoding rules for converting 'version 4' J1939 diagnostic messages (DM1, DM2, ...) to 'physical values'. This lets you identify issues in e.g. trucks, tractors and buses.
DBC is a CAN database format used in most automotive tools - incl. our CAN software/APIs.
The download includes a legal J1939-73 DBC and license, based on the J1939-73 PDF standard (also included). We offer this in collaboration with SAE.
-
RT-Labs - FSoE (SLAVE)0,00 €
SIL3 certified Safety-over-EtherCAT safety communication layer primarily for EtherCAT networks.
-
acontis - EC-Master Feature Packs0,00 €
Watch the video
EC-Master Tutorial: Getting Started with EC-Master On Windows -
RT-Labs - FSoE (MASTER)0,00 €
SIL3 certified Safety-over-EtherCAT safety communication layer primarily for EtherCAT networks.
-
acontis - EC Simulator0,00 €
The EC-Simulator virtualizes EtherCAT® networks by simulating the EtherCAT® slave devices in order to run EtherCAT Master applications without real EtherCAT® slave hardware available.
The EtherCAT® simulation is provided on a physical network adapter or virtually, e.g. to realize a completely simulated machine setup. Configuring the simulation instance is seamless using the ENI file of the real network.
Reaction to Process Data, SDOs, Slave Stack interaction, etc. can be programmed using C/C++ or .NET opening the EtherCAT data to various other engineering, testing or virtualizing tools like ISG Virtuos®.